2021 Journal Article
Stable High-Speed Quadrotor Flight using Differential Trajectory
Mathematical Problems in Engineering, vol. 2021, no. 1, article 9825790, 2021.
DOI: 10.1155/2021/9825790
Abstract
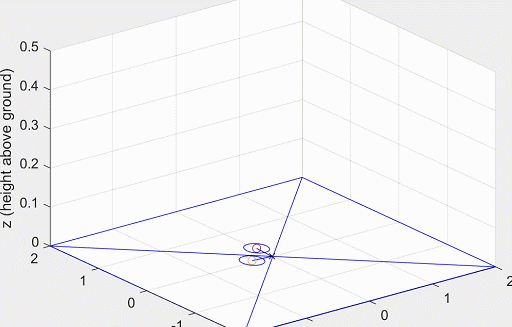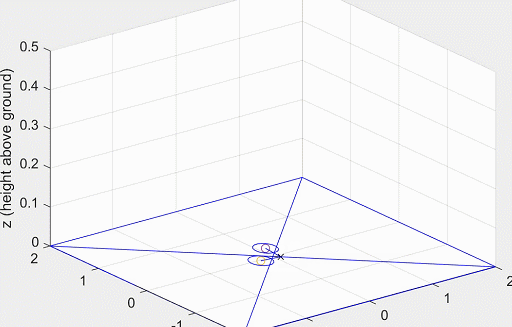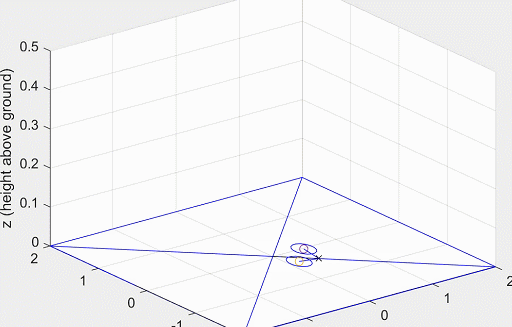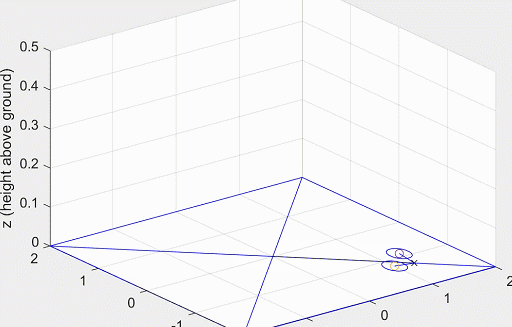
This paper addresses the trajectory tracking control issue of a quadrotor with environmental disturbances, which particularly focuses on attitude correction during flight and response speed improvement. In this paper, the proposed control method uses the differential equation to transform the desired trajectory for improving the robustness of a quadrotor during high-speed flight. Meanwhile, a nonlinear controller based on the rotation matrix is designed to avoid singularities of Euler angles. The controller can also stabilize the position error to zero without reducing the control thrust when the attitude error is large. Finally, we conduct simulations on a tethered quadrotor to achieve high-speed flight in limited space. The simulation results show that the control method can stabilize a quadrotor at high-speed trajectory flight and keep a quadrotor stable when it is disturbed by aerodynamic drag and mass change.
Links
Video to be added.
BibTeX
Download .bib@article{Wu2021StableQuadrotorFlight,
title = {{Stable High-Speed Quadrotor Flight using Differential Trajectory}},
author = {Ying Wu and Yun Xie and Sen Li and Depei Wang},
journal = {Mathematical Problems in Engineering},
year = {2021},
volume = {2021},
number = {1},
doi = {10.1155/2021/9825790},
pages = {9825790},
url = {https://onlinelibrary.wiley.com/doi/10.1155/2021/9825790}
}
If the preview does not load, open the PDF in a new tab or download it.