2021 Journal Article
Biomimetic Flip-and-Flap Strategy of Flying Objects for Perching on Inclined Surfaces
IEEE Robotics and Automation Letters, vol. 6, no. 3, pp. 5199–5206, 2021.
Abstract
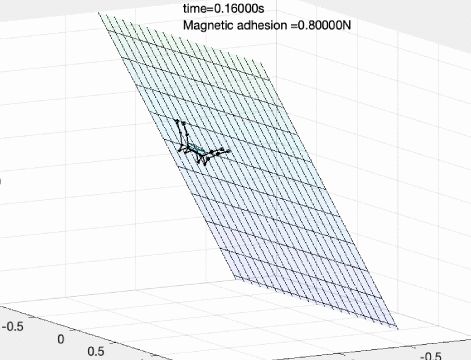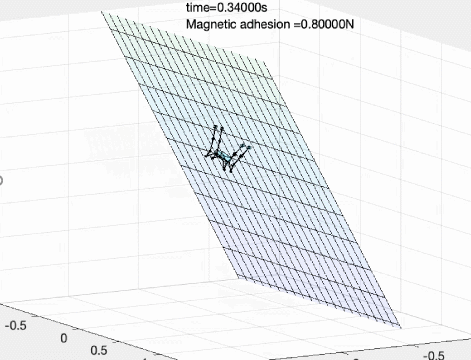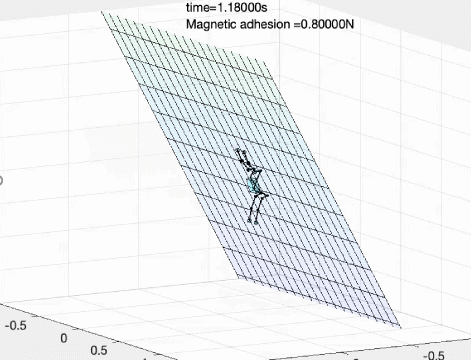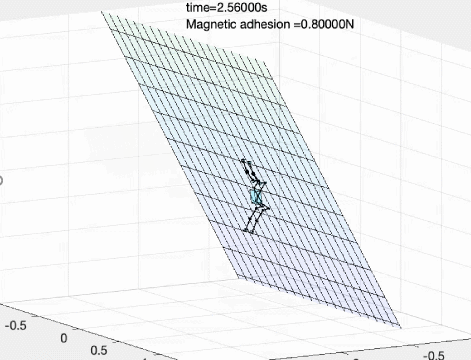
Animals can use the maneuver of a flipping body and flapping wings to reduce the normal rebound force of impact during landing, decreasing the adsorption force required by the contact point. This capability aids aerial vehicles with landing not only on vertical surfaces, but also on inclined surfaces. In this study, a “flip-and-flap” biomimetic strategy is presented that enables a high-speed flying object to perch on inclined surfaces without speed reduction before touchdown. During perching, the kinetic energy of the aerial vehicle is first converted to potential energy by flipping upward with a customized extended leg. Then, with a controlled thrust, the potential energy is consumed during the downward-swing phase. Thus, the aerial vehicle can land smoothly on a wall. Simplified and multilink models were designed to simulate the landing of a flying object, and the dynamic interaction between the flying object with an extended-leg mechanism and the surface was elaborated. A set of experiments on perching performed with the proposed strategy and customized extended leg, demonstrating the effectiveness and robustness of the strategy.
Links
BibTeX
Download .bib@article{Huang2021FLIPANDFLAP,
title = {{Biomimetic Flip-and-Flap Strategy of Flying Objects for Perching on Inclined Surfaces}},
author = {Zhifeng Huang and Sen Li and Jungao Jiang and Ying Wu and Liang Yang and Yun Zhang},
journal = {IEEE Robotics and Automation Letters},
year = {2021},
volume = {6},
number = {3},
pages = {5199--5206},
doi = {10.1109/LRA.2021.3070254},
url = {https://ieeexplore.ieee.org/document/9392363}
}
If the preview does not load, open the PDF in a new tab or download it.